
Warning!!! In standalone controllers, torque is not transmitted correctly via canbus and the internal torque calculation in the TCU must be correctly calibrated
TCU Configuration #
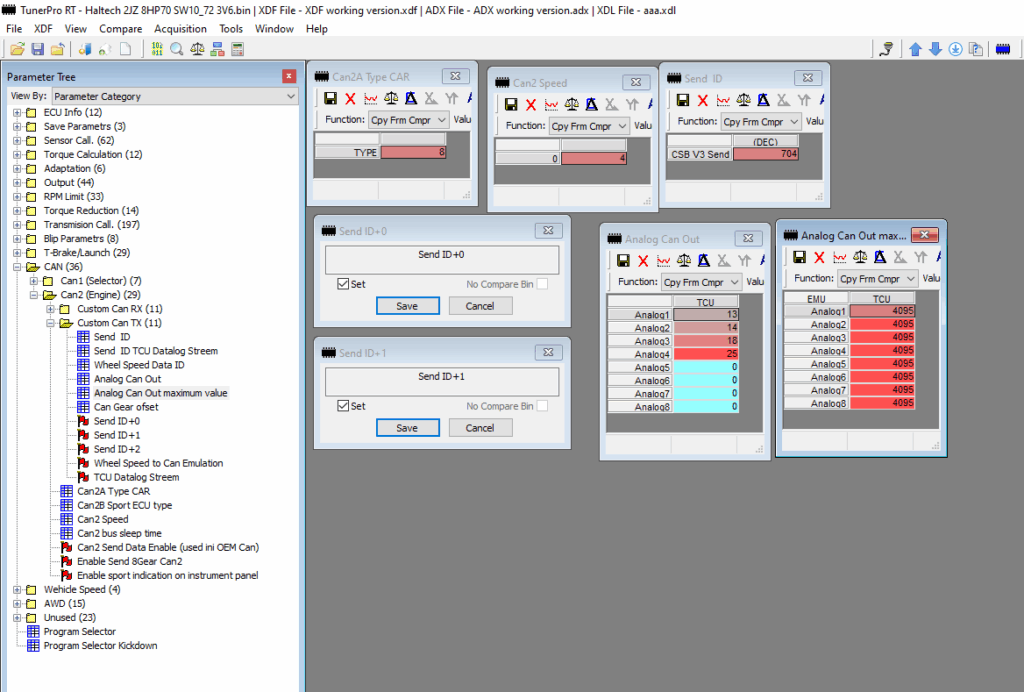
If your car is using Drive by wire set DBW input (Sensor Call. -> Sensor Input ) to 13. If not leave it a 0
CAN bus setup:
- Can2A Type CAR: 8
- Can2 Speed: 4
- Custom Can TX :
- Send ID: 704
- Analog Can Out maximum value: 4095
- Send ID+0: Set
- Send ID+1: Set
Haltech configuration #
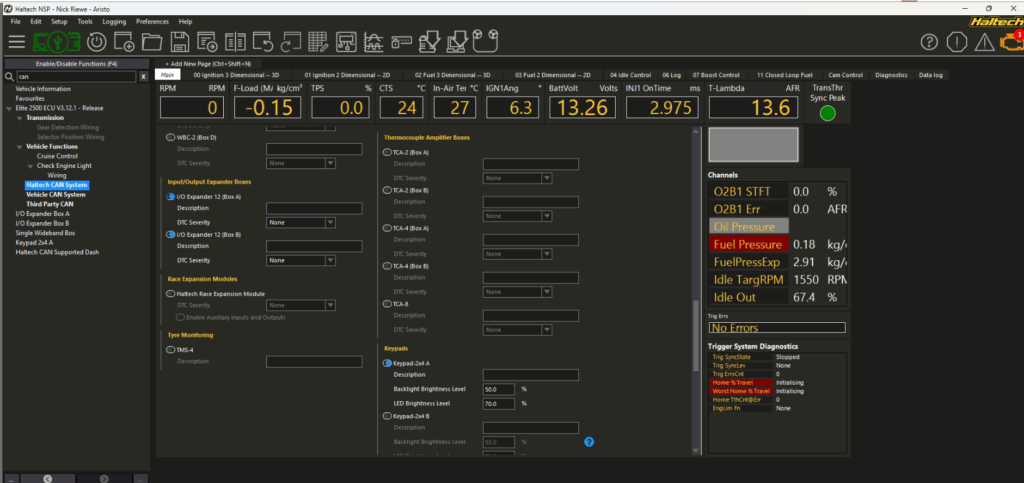
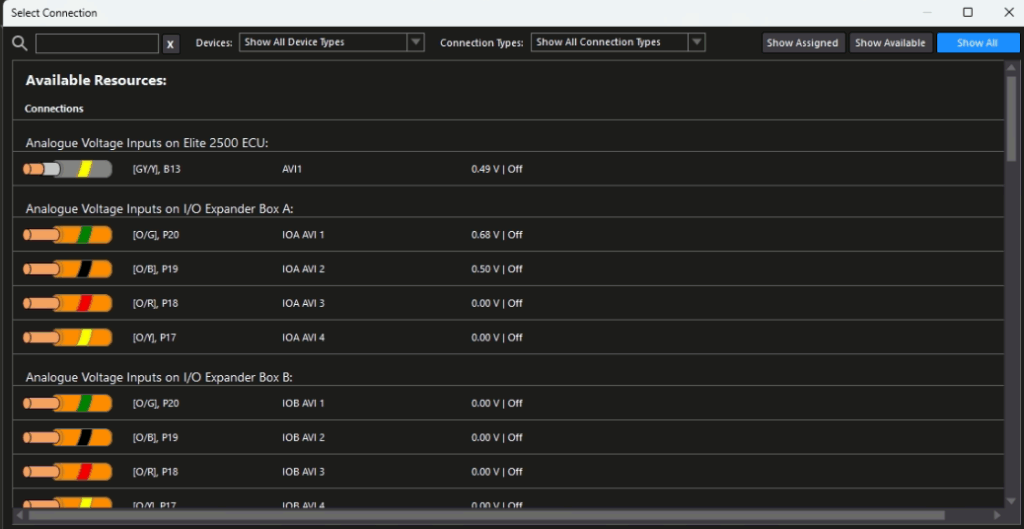
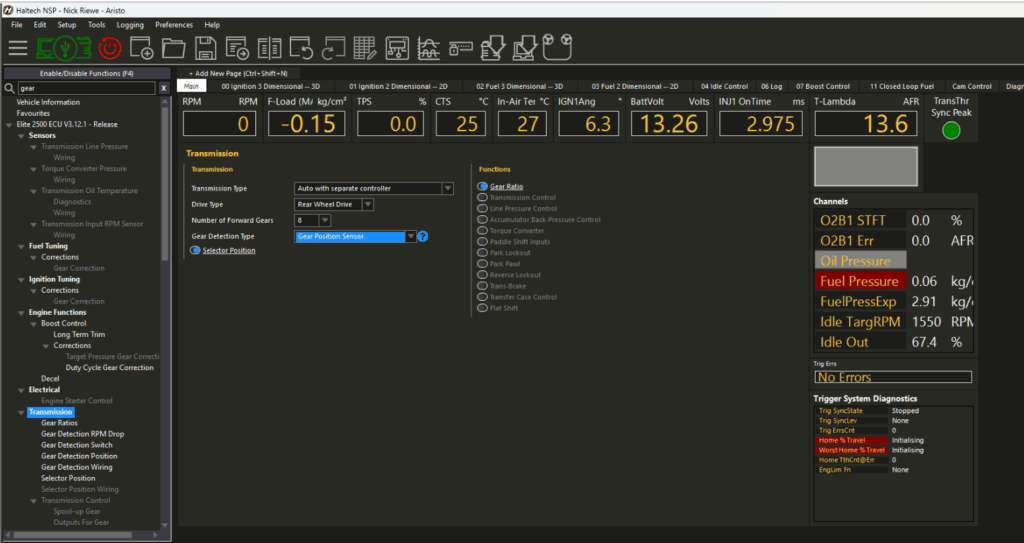
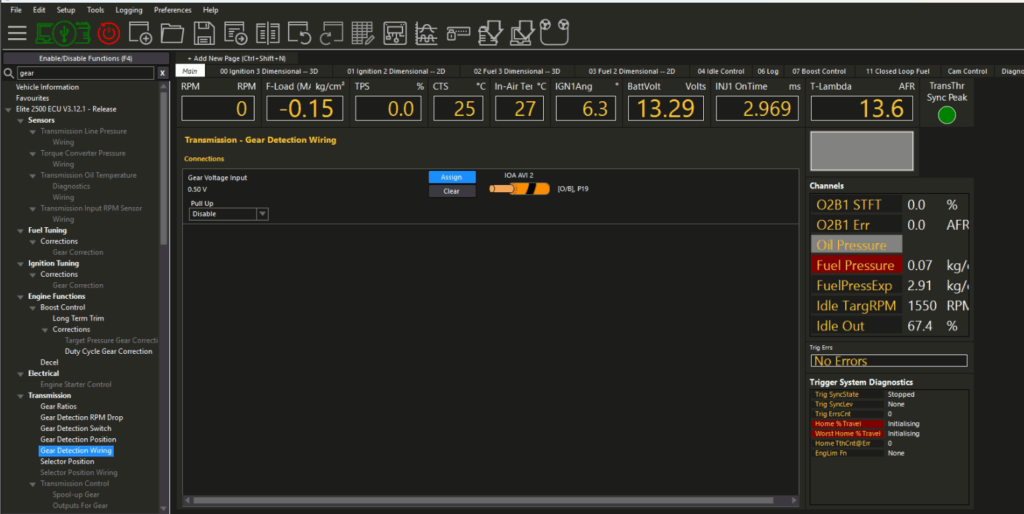
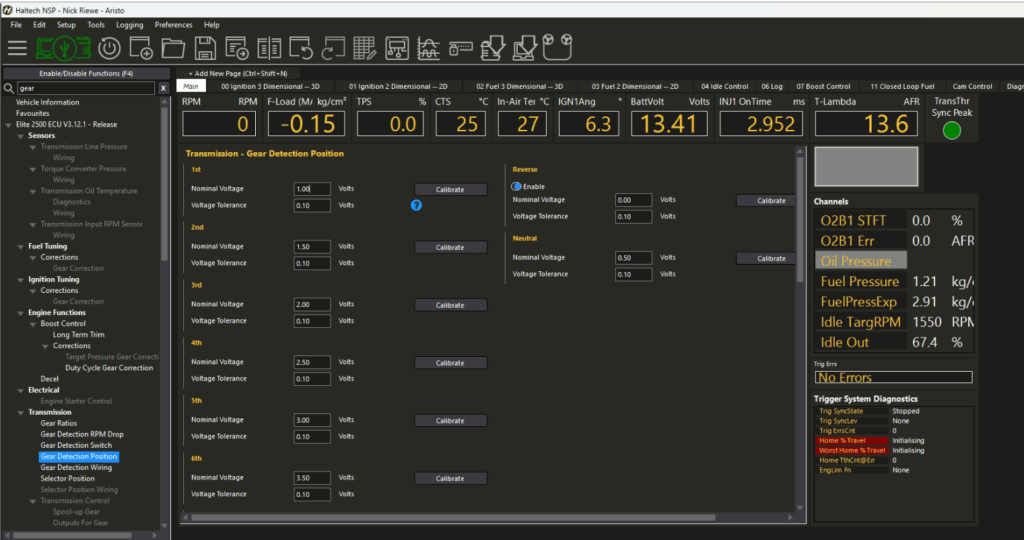
Torque reduction configuration example:
activate “Generic 1 Correction”

Configure axis:

Example torque reduction map

Warning! If after configuring the canbus the parameters in the TCU flash, it may mean that there is a canbus frames conflict, try changing the canbus address in the TCU and ECU.